Soft Gripper for Automated Dental Aligner Picking
Dental aligners may look simple to handle. But once you place them into a tray and try to automate the picking process, things become more complicated.They are thin, lightweight and flexible, with a curved shape that can easily deform under excessive force. At the same time, multiple aligners are usually arranged closely in the tray, making it important to pick one piece without disturbing the others.For this type of application, a soft gripper offers a different approach to automated handling.
Picking Dental Aligners from a Tray
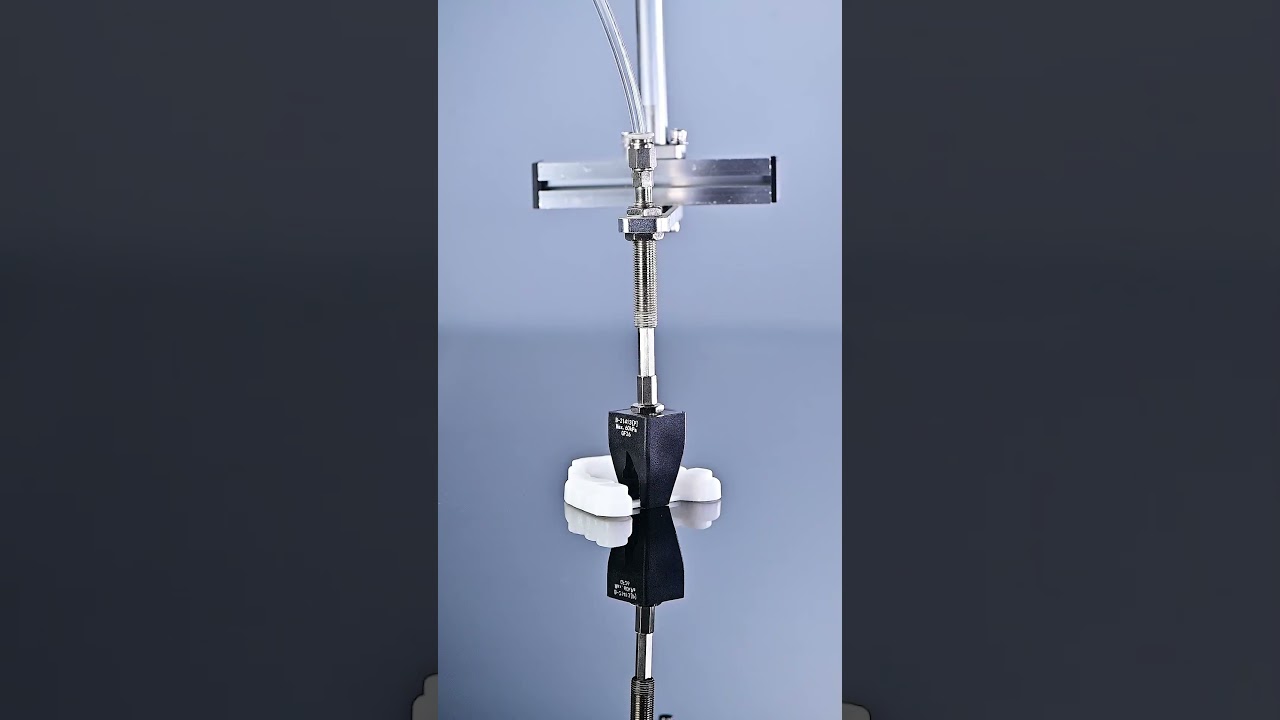
In this application, the dental aligners are placed in a tray for automated picking.The soft gripper approaches the target aligner and gently closes around the workpiece.Unlike a rigid gripping mechanism with fixed contact points, the soft fingers can deform during contact and conform more naturally to the curved surface of the aligner.This allows the gripper to establish contact without requiring a large clamping force.The goal is simple:Pick one aligner, keep it stable, and leave the surrounding aligners where they are.
How a Soft Gripper Handles Dental Aligners
The compliance of the soft fingers is particularly useful for flexible plastic parts.When the fingers make contact with the aligner, they can adapt to its shape instead of forcing the workpiece against a rigid gripping surface.This creates a more distributed contact area and helps reduce localized pressure.For tray picking, this flexibility also provides some tolerance when the aligner's position or orientation is not exactly the same from cycle to cycle.That can be useful in applications where workpieces have small variations in placement.
From Manual Picking to Automated Handling
Dental aligners are often handled manually during different stages of production.Moving this process to automation can help reduce repetitive manual operations and create a more consistent material-handling process.A typical automated workflow can include:Tray → Robotic Pickup → Transfer → Inspection / Processing / PackagingThe gripper becomes the connection between the robot and the workpiece.For flexible products such as dental aligners, that connection needs to be gentle enough to protect the part while still providing enough grip for reliable movement.