Soft Gripper + Soft Wing for Mooncake Picking: A Flexible Approach to Food Handling Automation
A mooncake doesn’t look particularly difficult to pick up.You can simply reach out and pick one up by hand. But when the same task is handed over to a robot, things become a little different.Mooncakes often have textured surfaces, and some varieties are relatively soft. Their edges may not always be perfectly uniform, either. Apply too much gripping force, and the surface can be marked or deformed. Apply too little, and the product may shift or even fall during transfer.For this test, we used a soft gripper + soft wing combination for robotic mooncake picking.The soft gripper handles the main gripping action, while the soft wing adds extra contact and support.As the soft gripper closes, the flexible structure can conform to the shape of the mooncake. Instead of simply holding the product between two sides, the gripper provides a larger supporting contact area.That makes a difference when handling softer food products.In simple terms:The soft gripper grips. The soft wing supports.Working together, they help distribute the gripping force over a larger contact area, reducing concentrated pressure at individual points.
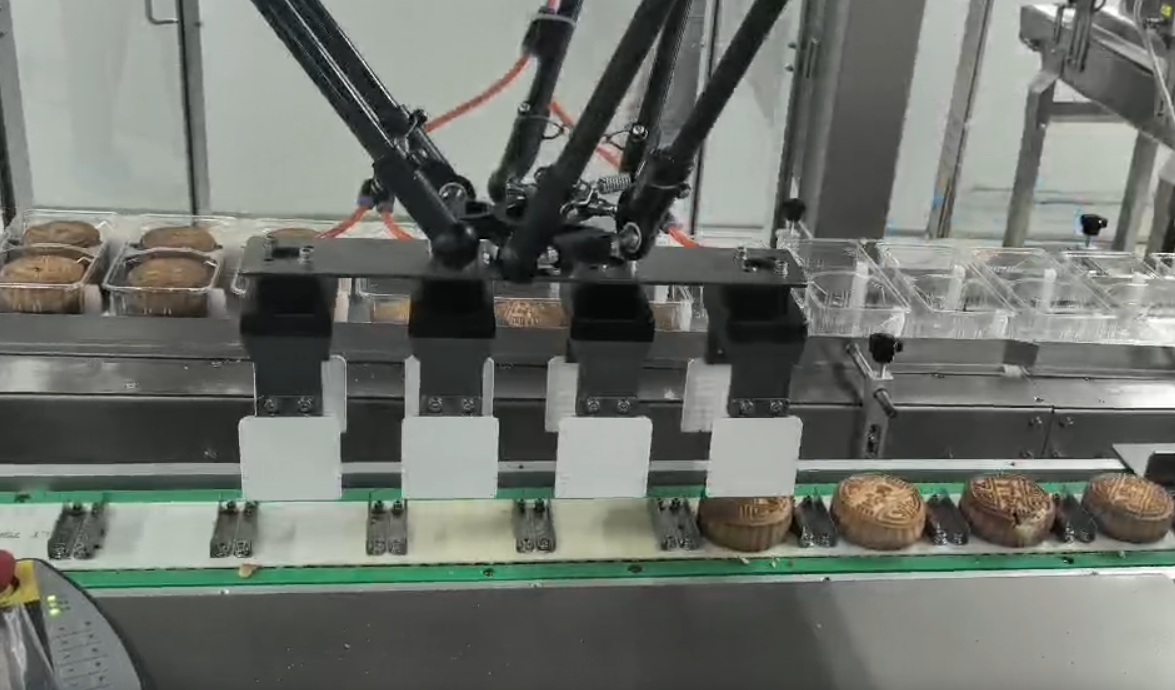
From Clamping to Conforming Support
During the picking process, the soft gripper approaches the mooncake from both sides. Once the flexible gripping structure makes contact, it gradually conforms to the product.The soft wing provides additional support from the side.Compared with a traditional rigid gripper that relies on several fixed contact points, this approach offers more flexibility when dealing with variations in product shape.This becomes particularly useful when mooncake dimensions are not exactly identical. The gripping process does not have to rely entirely on a highly precise fixed contact position.For an automated production line, that is a practical consideration.Once a product moves into real production, it is rarely going to have exactly the same size and shape every single time.
Picking Is Only Part of the Process
Food automation does not end when a product is picked from point A and moved to point B.After the mooncake is picked, it still needs to be transferred, positioned, and placed into its packaging. If the product rotates or shifts during picking and movement, that can affect the next step of the process.So for this application, the question was not simply:Can the robot pick up the mooncake?It was also:Can it carry the mooncake steadily to the next step?The soft gripper and soft wing work together to provide additional support during movement, helping keep the mooncake stable while reducing unnecessary pressure on the product surface.
More Possibilities for Soft Gripping in Food Automation
Mooncakes are just one example.Similar issues can appear when automating the handling of bread, pastries, biscuits, and soft packaged food products.The product may not tolerate strong clamping.Its dimensions may vary slightly.Its surface may be sensitive to contact marks.At the same time, the product still needs to be transferred reliably.In these applications, a gripper is not simply about how tightly it can clamp.How it contacts the product, how much area it contacts, and where the gripping force is distributed all matter.The combination of a soft gripper and soft wing is one way to approach these requirements with a more flexible gripping structure.For food products with different sizes, shapes, and material characteristics, the soft gripper structure, soft wing configuration, and gripping method can be adjusted according to the specific application.That gives robotic food handling systems more flexibility when one fixed gripping method is not enough.