Soft Robotic Gripper for Cigar Handling: A Gentle and Adaptive Gripping Solution
Cigars may look simple to handle, but automating their transportation presents a few unique challenges.They are lightweight, slender, cylindrical, and often require careful handling to avoid unwanted deformation or surface damage. When different cigar sizes need to be processed on the same production line, the gripping system also needs enough flexibility to accommodate variations in dimensions.In this case, a soft robotic gripper was used to automate the handling of cigars ranging from 100–200 mm in length, 12–25 mm in diameter, and approximately 8–16 g in weight.
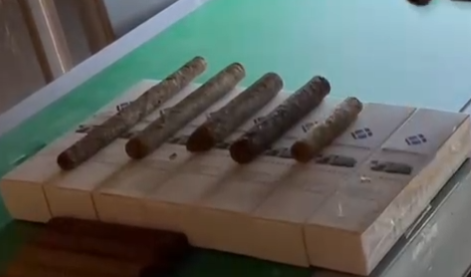
Why Is Cigar Handling Challenging?
Lightweight and Slender Products
Cigars have a relatively large length-to-diameter ratio.Although their weight is only around 8–16 g, their slender shape means that an unstable grip can cause the product to shift or rotate during transportation, especially when the robotic arm accelerates, decelerates, or changes direction.The gripper therefore needs to provide sufficient holding force without applying unnecessary pressure.
Avoiding Excessive Local Pressure
For many industrial components, increasing gripping force is a straightforward way to improve stability.Cigars are different.Excessive or concentrated pressure can potentially leave marks or deform the product. This makes the contact method just as important as the gripping force itself.Instead of simply asking:“How tightly can we grip it?”The better question is:“How gently can we grip it while keeping it stable?”
Different Product Dimensions
The cigars in this application vary in size:
- Length: 100–200 mm
- Diameter: 12–25 mm
- Weight: approximately 8–16 g
A conventional rigid gripper with a fixed gripping profile may require frequent adjustments or different tooling when product dimensions change.For automated production lines handling multiple specifications, this can increase setup and changeover requirements.
How Does a Soft Gripper Handle Cigars?
A soft robotic gripper approaches the problem differently.Instead of relying on rigid gripping surfaces and fixed contact points, its flexible fingers can deform around the product and adapt to its cylindrical shape.As the gripper closes, the soft fingers conform to the outer surface of the cigar, creating a larger and more distributed contact area.This allows the gripper to maintain a stable hold while reducing the need for high localized gripping pressure.
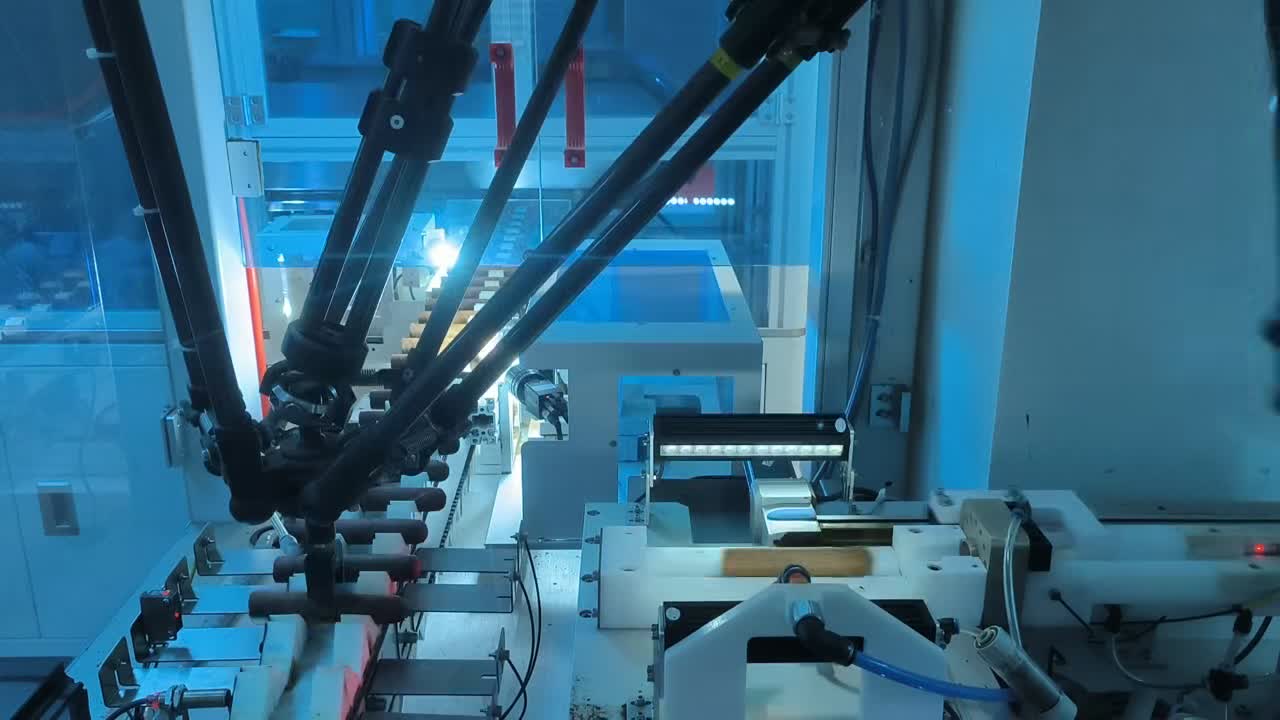
Key Advantages of Soft Robotic Gripping
1. Gentle Contact
The soft gripping surface provides a compliant interface between the gripper and the product.This is particularly useful for applications where excessive mechanical pressure should be avoided.
2. Adaptive Gripping
The flexible fingers can accommodate variations in product diameter, making the gripper suitable for handling different cigar specifications without relying entirely on a rigid, fixed gripping profile.
3. Stable Transportation
A larger contact area helps distribute the gripping force across the product rather than concentrating it at a few rigid contact points.This can help maintain stability during robotic movement.
4. Flexible for Multi-Size Applications
With cigar dimensions ranging from 12 to 25 mm in diameter and 100 to 200 mm in length, adaptability becomes an important factor.A soft gripper can provide a more flexible gripping approach when multiple product sizes need to be handled within the same automation system.
From “Gripping” to “Gentle Handling”
This cigar handling application demonstrates an important principle in automated gripping:Gripping force is not the only consideration. How that force is applied matters just as much.Rigid grippers remain an excellent choice for many conventional industrial applications. However, when products are lightweight, slender, surface-sensitive, or available in multiple sizes, a compliant gripping solution can offer a different approach.By combining soft contact, adaptive deformation, and controlled gripping force, soft robotic grippers can help automate the handling of delicate cylindrical products while maintaining a balance between stability and gentle contact.Looking for a gripping solution for lightweight or surface-sensitive products?Rochu Soft Robotic Grippers are designed to adapt to a wide range of workpieces and gripping conditions.