Handling Different Watch Cases with a Soft Robotic Gripper
Watch cases come in different shapes, sizes, and finishes. Some are made of mirror-polished stainless steel, while others use titanium alloy. They may look similar, but handling them on the same production line is not always that simple.
One thing we had to consider in this application was how to grip these cases without leaving marks on their surfaces.
Conventional pneumatic grippers use relatively rigid fingertips. When handling polished watch cases, even a small amount of unwanted contact can leave scratches. The curved edges add another challenge. With a surface radius of around 3–8 mm, a fixed fingertip may only make contact with a small area, resulting in uneven pressure.
So, instead of using a fixed gripping shape, we used adjustable soft gripper Modules.

The gripping position can be adjusted to fit different watch case sizes, which means there is less need to prepare separate gripping parts for every model. The project configuration is expected to reduce spare parts inventory by around 30%.
The contact material also matters. We used bionic silicone with non-marking properties to make contact with the polished surfaces. An anti-static material configuration was included as well, since static electricity can attract dust during high-speed handling. The application notes recorded a 12% contamination rate as one of the issues to address.
There is also the flipping process to consider.With conventional pneumatic cylinder grippers, the gripping position may shift by around 0.2–0.5 mm during flipping. That may not sound like much, but it can affect the next clamping step, especially when positioning accuracy matters.
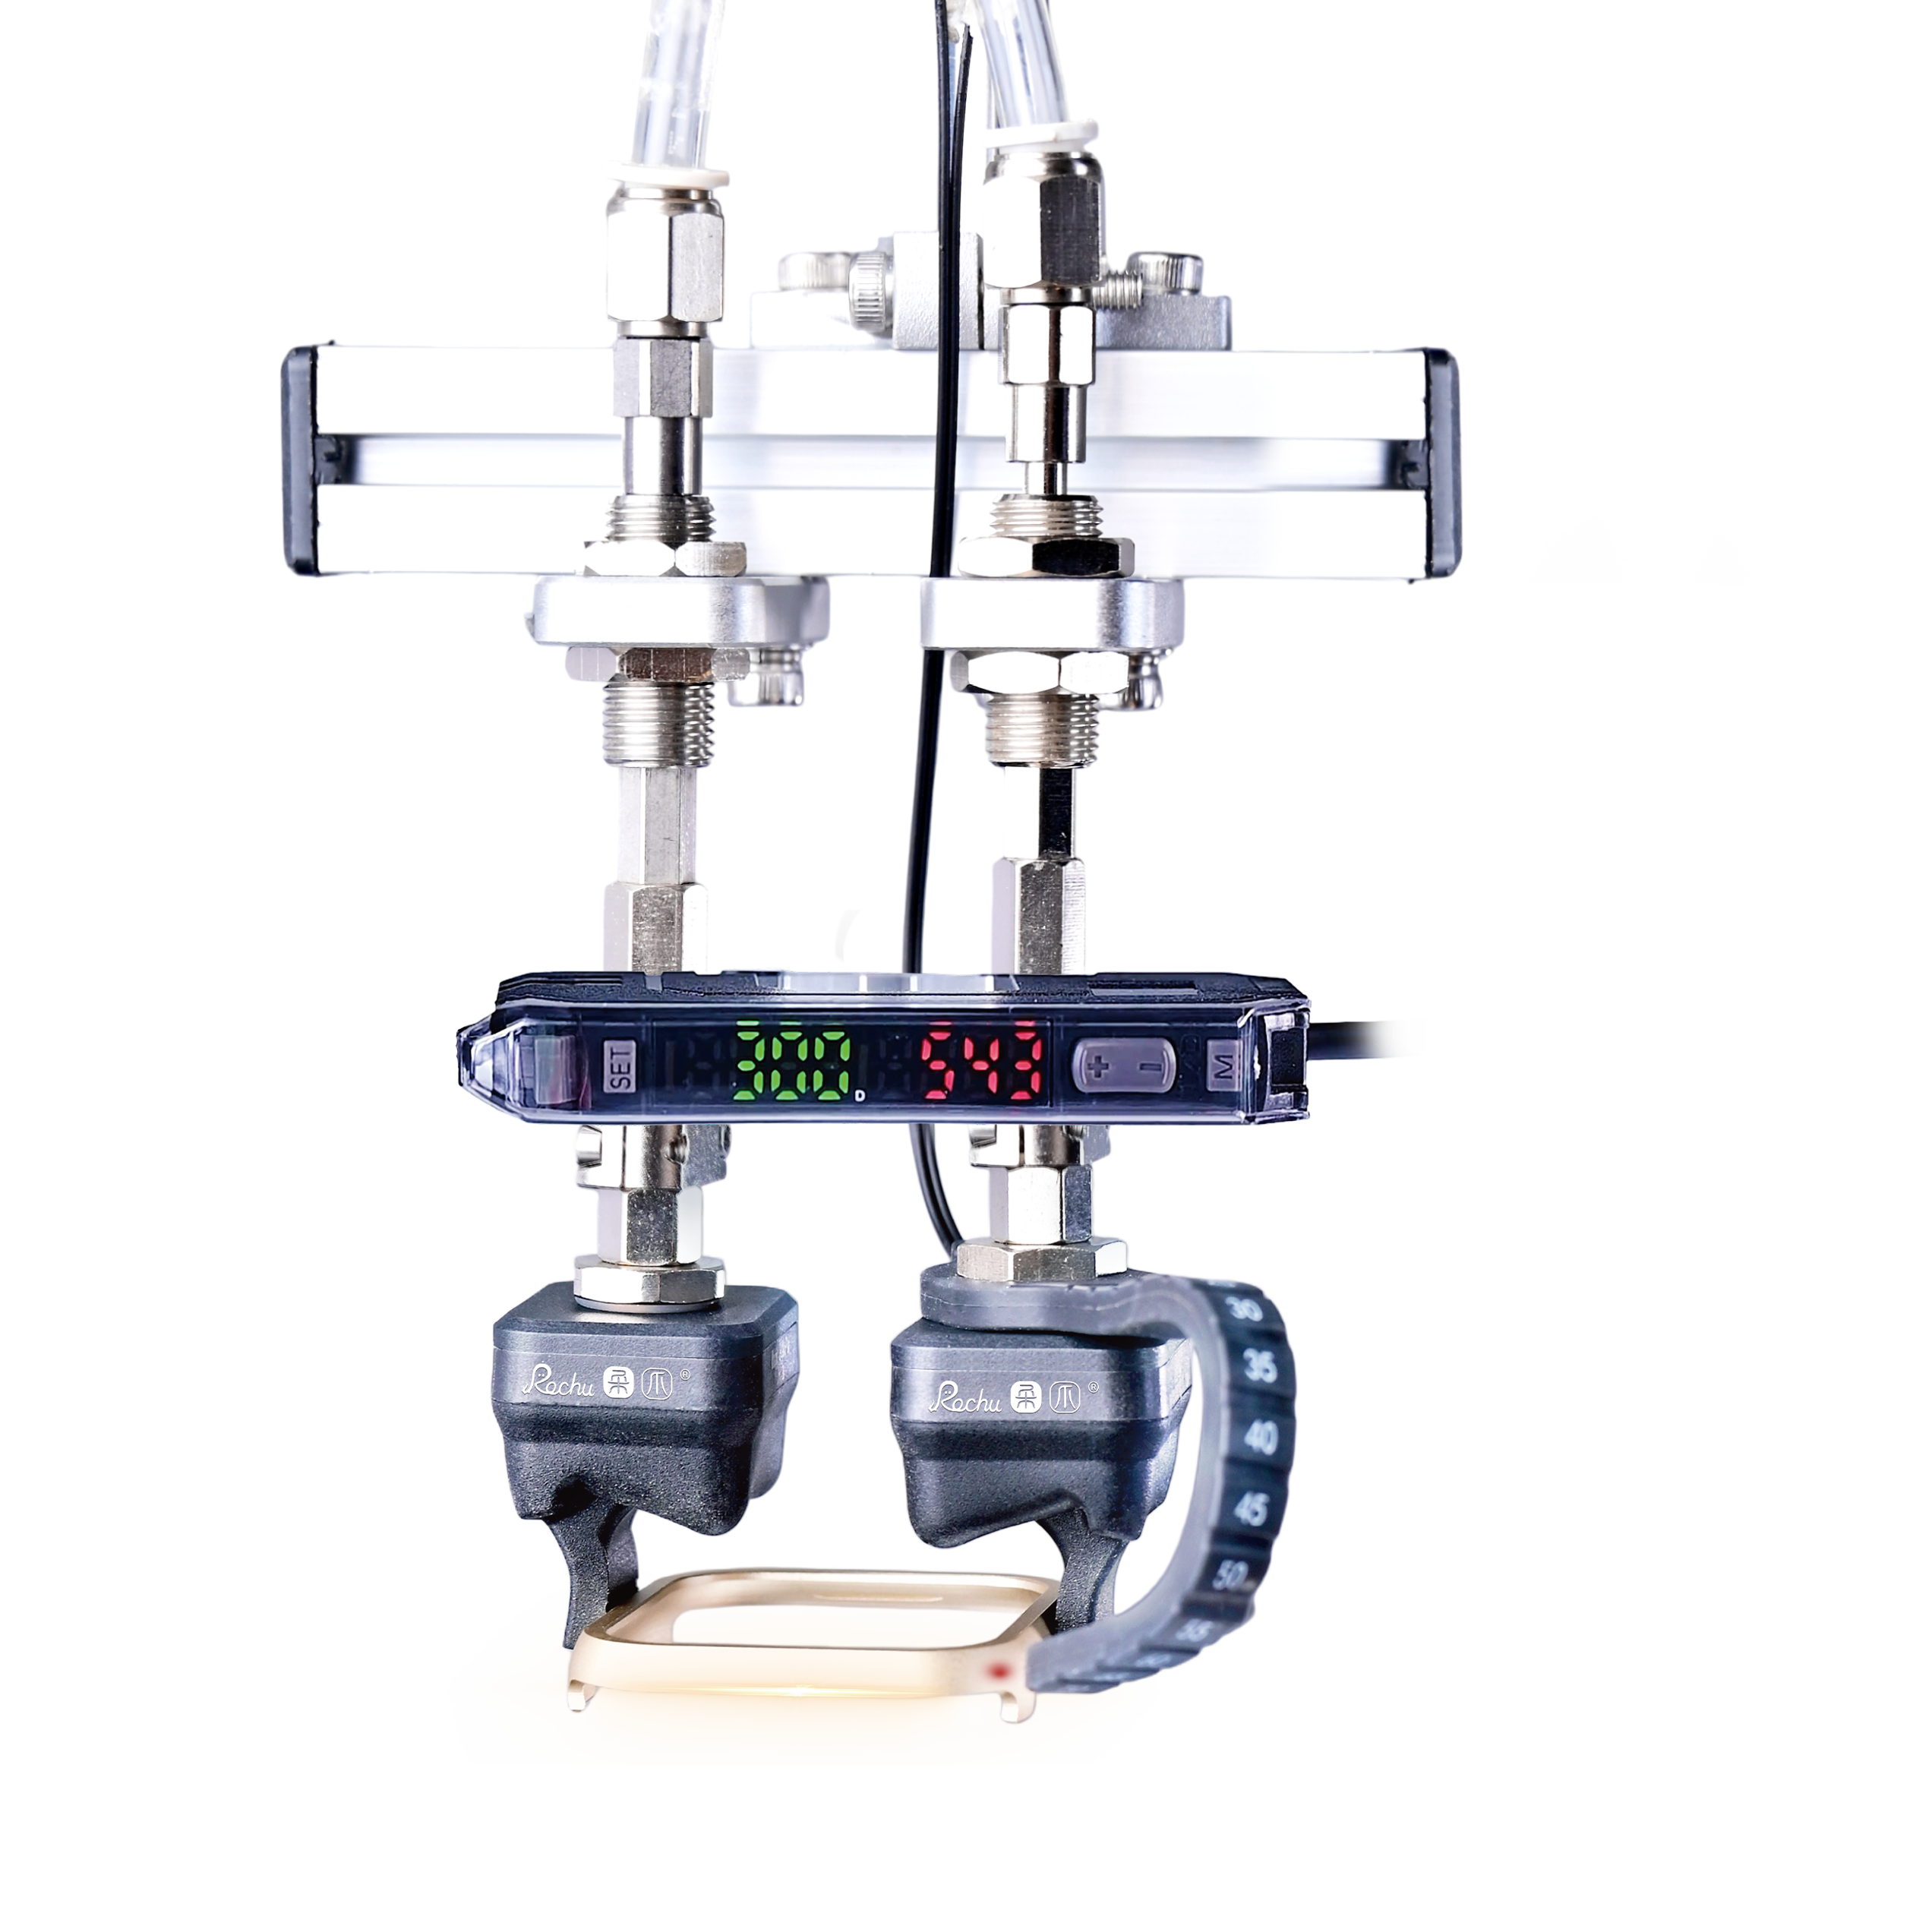
For this setup, the gripping system was configured with two Beak Modules, together with flexible probes and an optical fiber signal amplifier for the inspection-related process.Configuration used:
| Component | Model | Qty. |
|---|---|---|
| Beak Module | DAC-1G3024[LHAS]/SN | 2 |
| Flexible Probe | SE-FP31 | 1 |
| Optical Fiber Signal Amplifier | SE-OF45N | 1 |
| Slide Mounting Plate | SMP-13 | 2 |
| Profile | P-R3030<500> | 1 |
| Connection Module | CM-S04 | 2 |
| Flange Connect Module | FCM-R03 | 1 |
For jobs like this, the details of the workpiece matter more than they might seem at first. Surface finish, curved edges, different sizes, and the movement required during handling all need to be considered when choosing the gripping structure.