Industry News #adaptive grasping
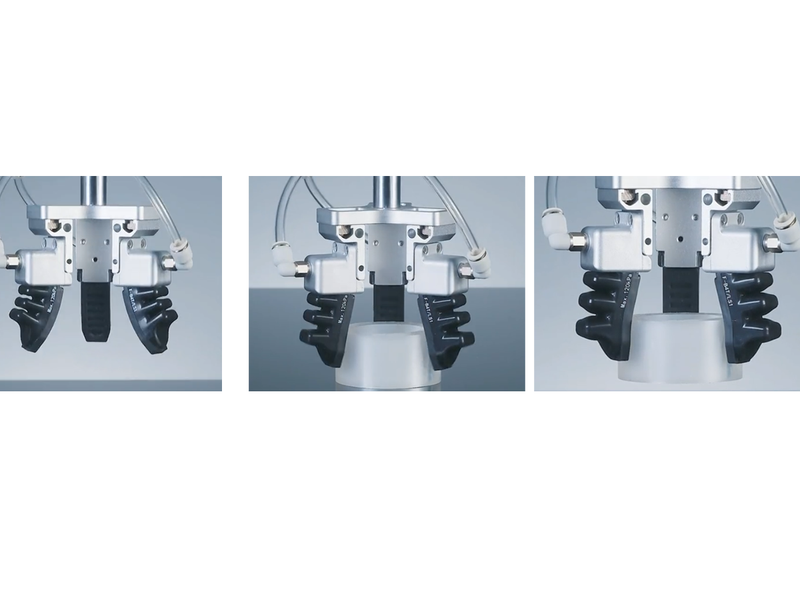
Discover how soft robotic grippers achieve adaptive grasping through flexible materials, structural design, actuation, and force control for handling different workpieces.
Read MoreDiscover how soft robotic grippers achieve adaptive grasping through flexible materials, structural design, actuation, and force control for handling different workpieces.
Read More