O-Ring Handling in Automotive Automation: An Application of Soft Grippers
O-rings are widely used in automotive components for sealing and connection purposes. Although they are small and lightweight, handling them in an automated production line can be more challenging than it looks.Their elastic material makes them easy to deform during gripping. At the same time, O-rings come in different diameters, which means the gripping solution needs to accommodate various sizes without requiring complicated changes to the equipment.In this application, a soft gripper is used to pick up O-rings from the inside, providing a practical approach to automated handling.
What Makes O-Ring Handling Challenging?
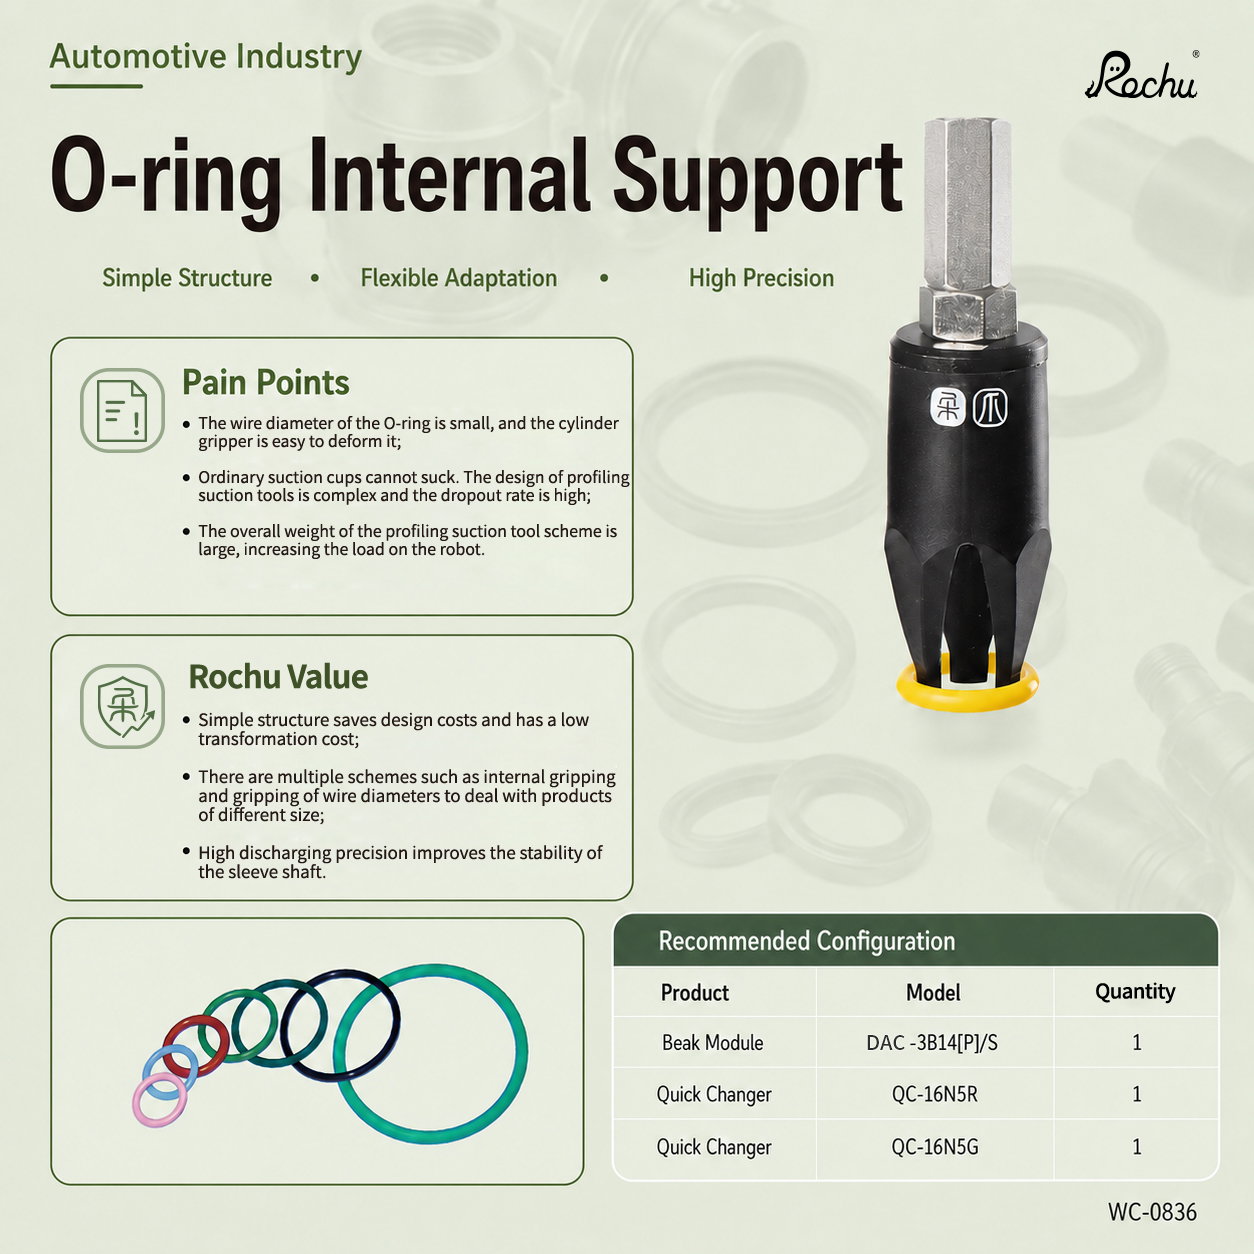
There are a few things to consider when designing an automated gripping process for O-rings.1. Small O-rings can easily deform during grippingO-rings are typically made of elastic materials. When using conventional pneumatic grippers, excessive gripping force may cause deformation, especially when handling smaller rings.2. Conventional suction cups are not always suitableDue to their shape and material, some O-rings are difficult to pick up with standard suction cups. Custom-shaped suction cups may be required, making the overall design more complicated and increasing the risk of dropped workpieces.3. Custom gripping systems can add weightSome customized suction solutions involve relatively complex structures. The additional weight can increase the load on the robot, which is another factor to consider when designing an automated workstation.
How Does a Soft Gripper Handle O-Rings?
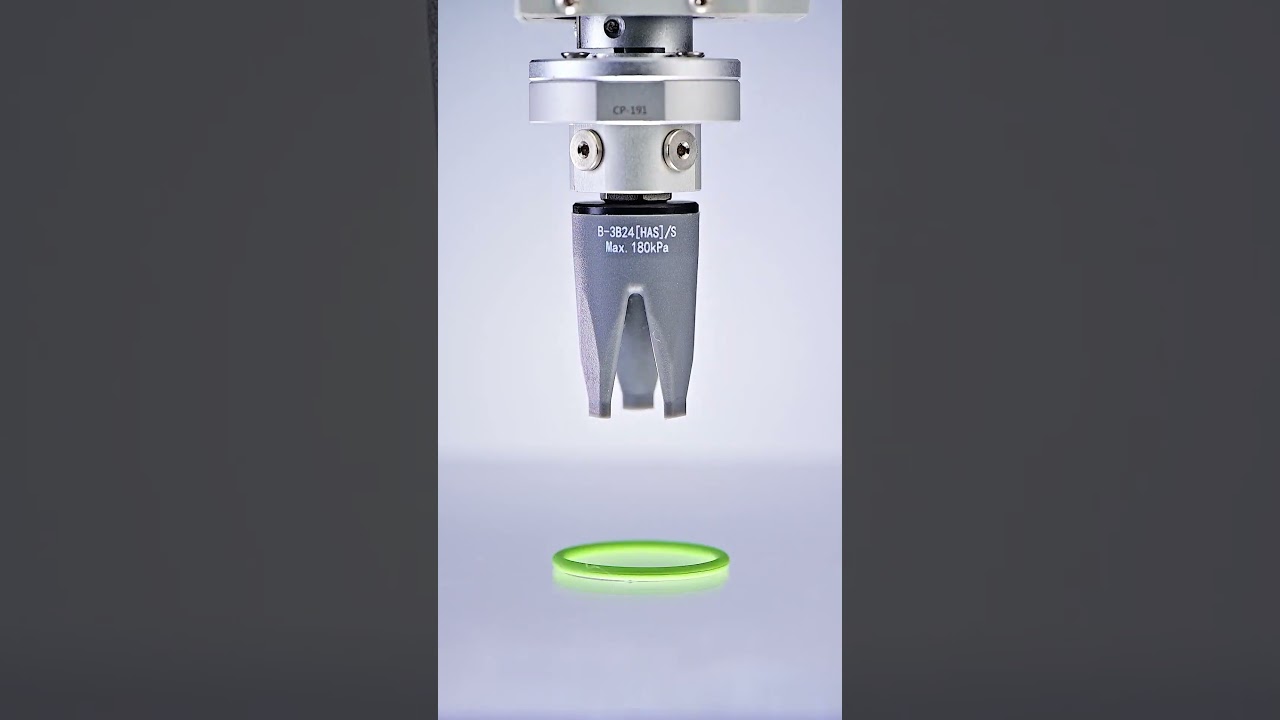
For this application, a soft gripper is used for internal gripping, picking up O-rings from their inner diameter.Instead of gripping the outer surface, the soft fingers enter the ring and expand to make contact with its inner wall. This approach allows the O-ring to be picked up from the inside while reducing the need for complex external gripping structures.There are three aspects worth noting:
- Simple structure: The soft gripper provides a relatively straightforward gripping setup, helping reduce equipment design and modification costs.
- Adaptable to different diameters: Internal gripping and different pickup arrangements can be considered to handle O-rings of various sizes.
- Stable release: Controlled gripping and release help improve placement accuracy, which is important when O-rings need to be fitted onto shafts.
Soft Grippers for Automotive Component Handling
O-ring handling is just one example of small-part automation in the automotive industry.Many automotive components have similar requirements. Some are elastic, some have irregular shapes, and others need to be positioned accurately during assembly.When selecting a robot gripper, it is worth looking beyond whether it can pick up a workpiece. The gripping method, compatibility with different sizes, release accuracy, and the overall weight of the setup can all affect the performance of an automated line.For O-rings, internal gripping with a soft gripper offers another option for simplifying the handling process.