Handling Multiple Spandex Paper Tubes with Soft Robotic Grippers
We recently came across an application involving the packaging of spandex paper tubes.The tubes themselves are not particularly heavy, but placing them neatly into a box can be more challenging than it looks.When the tubes need to be arranged closely together, picking them up one at a time means repeating the same pick-and-place operation over and over. Naturally, one way to improve the packaging process is to pick up multiple tubes in a single cycle.However, paper tubes have a hollow structure, and their outer walls can be easily deformed by excessive pressure. In this application, suction cups were not suitable for the required gripping conditions. Traditional rigid grippers also needed to be carefully designed around the gripping position and contact force.The solution was to use soft robotic grippers for external gripping.As shown in the image, multiple soft gripper modules are mounted on a single plate and arranged according to the layout of the paper tubes. The compact configuration allows several tubes to be picked up simultaneously within a limited space.There are two details worth looking at more closely.
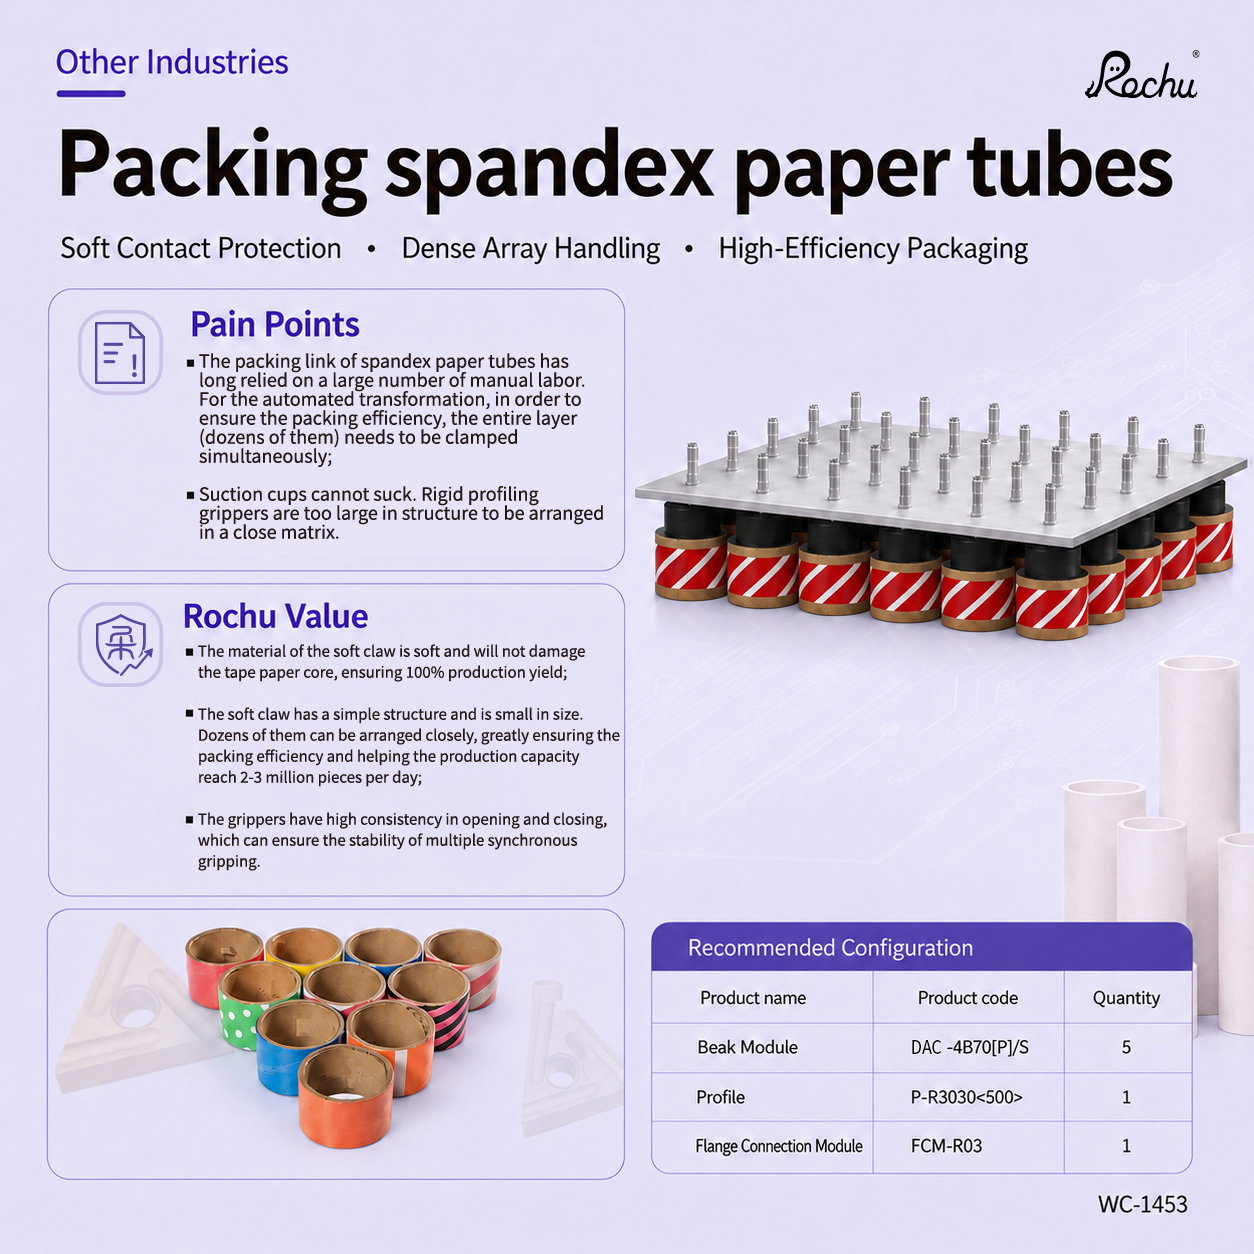
1. How the paper tubes are gripped
The soft grippers make contact with the outer surfaces of the tubes and deform slightly to conform to their shape.For this type of workpiece, applying more gripping force is not necessarily better. The goal is to hold the tubes securely without putting excessive pressure on their walls.This is particularly important when handling hollow cylindrical objects, where the gripping force and contact area need to be considered together.
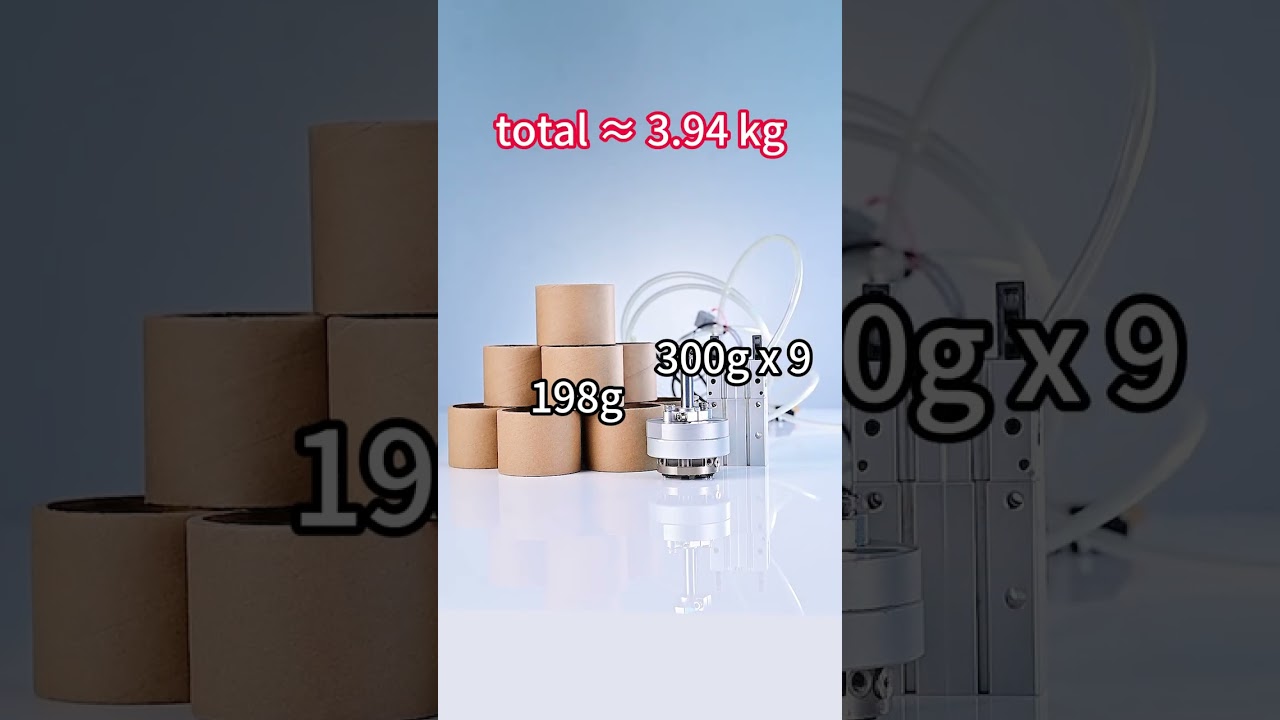
2. How the grippers are arranged
Picking up multiple workpieces at once is not simply a matter of adding more grippers.The spacing between the grippers, the available mounting space, and the arrangement of the tubes inside the packaging box all need to be considered.The gripper layout has to match the workpiece arrangement. Otherwise, even if the tubes can be picked up successfully, placing them into the box may still be difficult.This is what makes the application interesting. The workpieces themselves are relatively simple, but once several tubes need to be handled simultaneously, both the gripping method and the mechanical layout become important.For similar hollow cylindrical workpieces, these are also useful factors to consider during the design process. The appropriate gripping structure will depend on the tube dimensions, arrangement, and required handling cycle.#SoftRobotics #PackagingAutomation #SoftRoboticGripper