Soft Gripper for Picking Up Surgical Suture Needles from a Vibratory Bowl
Picking Up Small Surgical Needles Is Not as Easy as It Looks
Surgical suture needles are small, lightweight, and come in different sizes and curved shapes. In automated production, picking them up from a vibrating bowl can be a tricky task.The challenge is not simply gripping the needle. It is keeping a stable grip while the needle moves, tilts, or changes position during bowl feeding.Traditional pneumatic cylinder grippers can run into a few problems in this process:
- Different needle specifications: Short and long needles require different gripping positions. Frequent adjustments to the clamping parameters can make the process less convenient.
- Very lightweight workpieces: Surgical needles weigh less than 1 g. When the vibratory bowl is running, the needles may shift, making them difficult to pick up consistently. Excessive gripping force may also cause deformation or displacement.
- Curved surfaces and changing orientations: Needles do not always arrive in the same position. When a needle tilts or rotates, a rigid gripping structure may struggle to maintain stable contact.
How Does a Soft Gripper Handle It?
In this application, a Rochu soft gripper is used to retrieve surgical suture needles from a vibratory bowl.Instead of relying on rigid clamping, the soft gripper uses adaptive deformation to conform to different needle shapes and sizes. Combined with air pressure control, it helps maintain a stable grip while reducing the risk of scratches or damage to these delicate workpieces.Another important part is the flexible sensing system. With flexible sensors, the gripper can detect gripping status in real time and respond to changes in the needle's position and posture during feeding.For medical-related applications, the gripper also features an enclosed structure and medical-grade materials, helping reduce potential contamination and safety risks in the working environment.
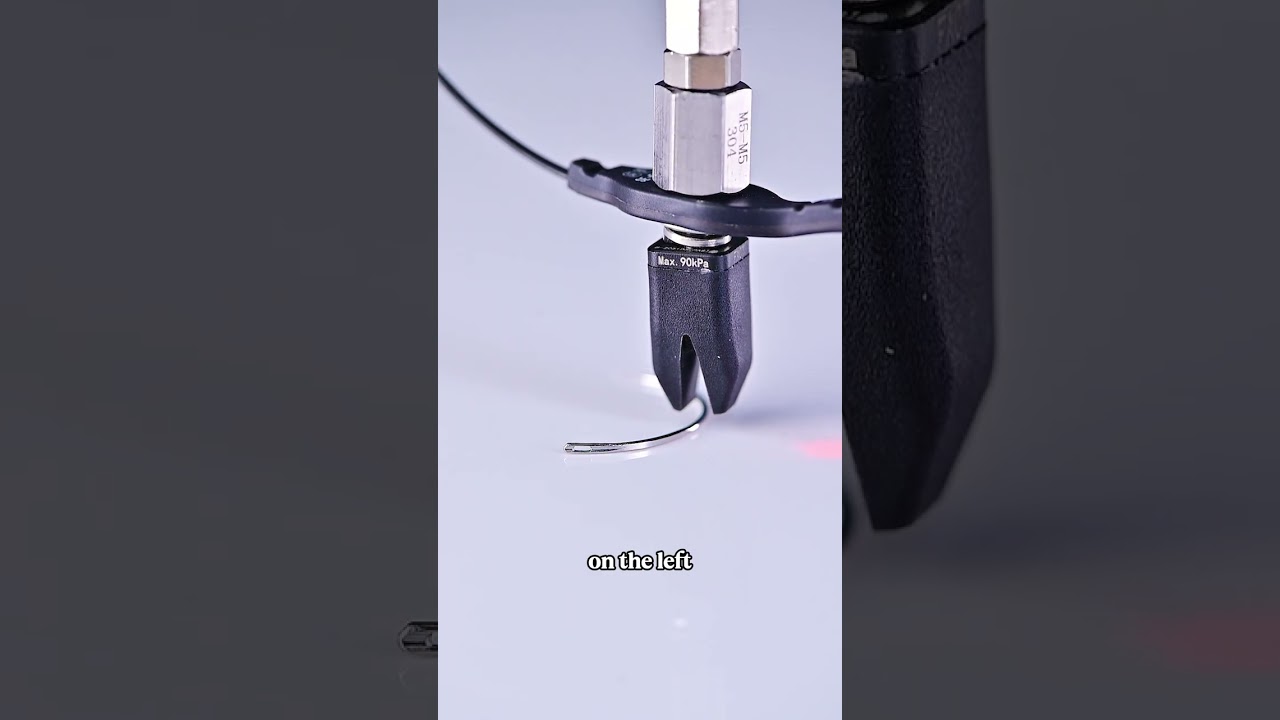
When handling delicate components, gripping force is only part of the equation. Shape, orientation, contact area, and changes during feeding all matter.This is where a soft gripper can offer a different approach to automated picking, especially when the workpieces are lightweight, curved, and available in multiple specifications.Sometimes, making the gripping process more adaptable is just as important as making it faster.