New Product Release | No Air Supply. No Robot Arm. No Programming. Just Grab — Anytime, Anywhere.
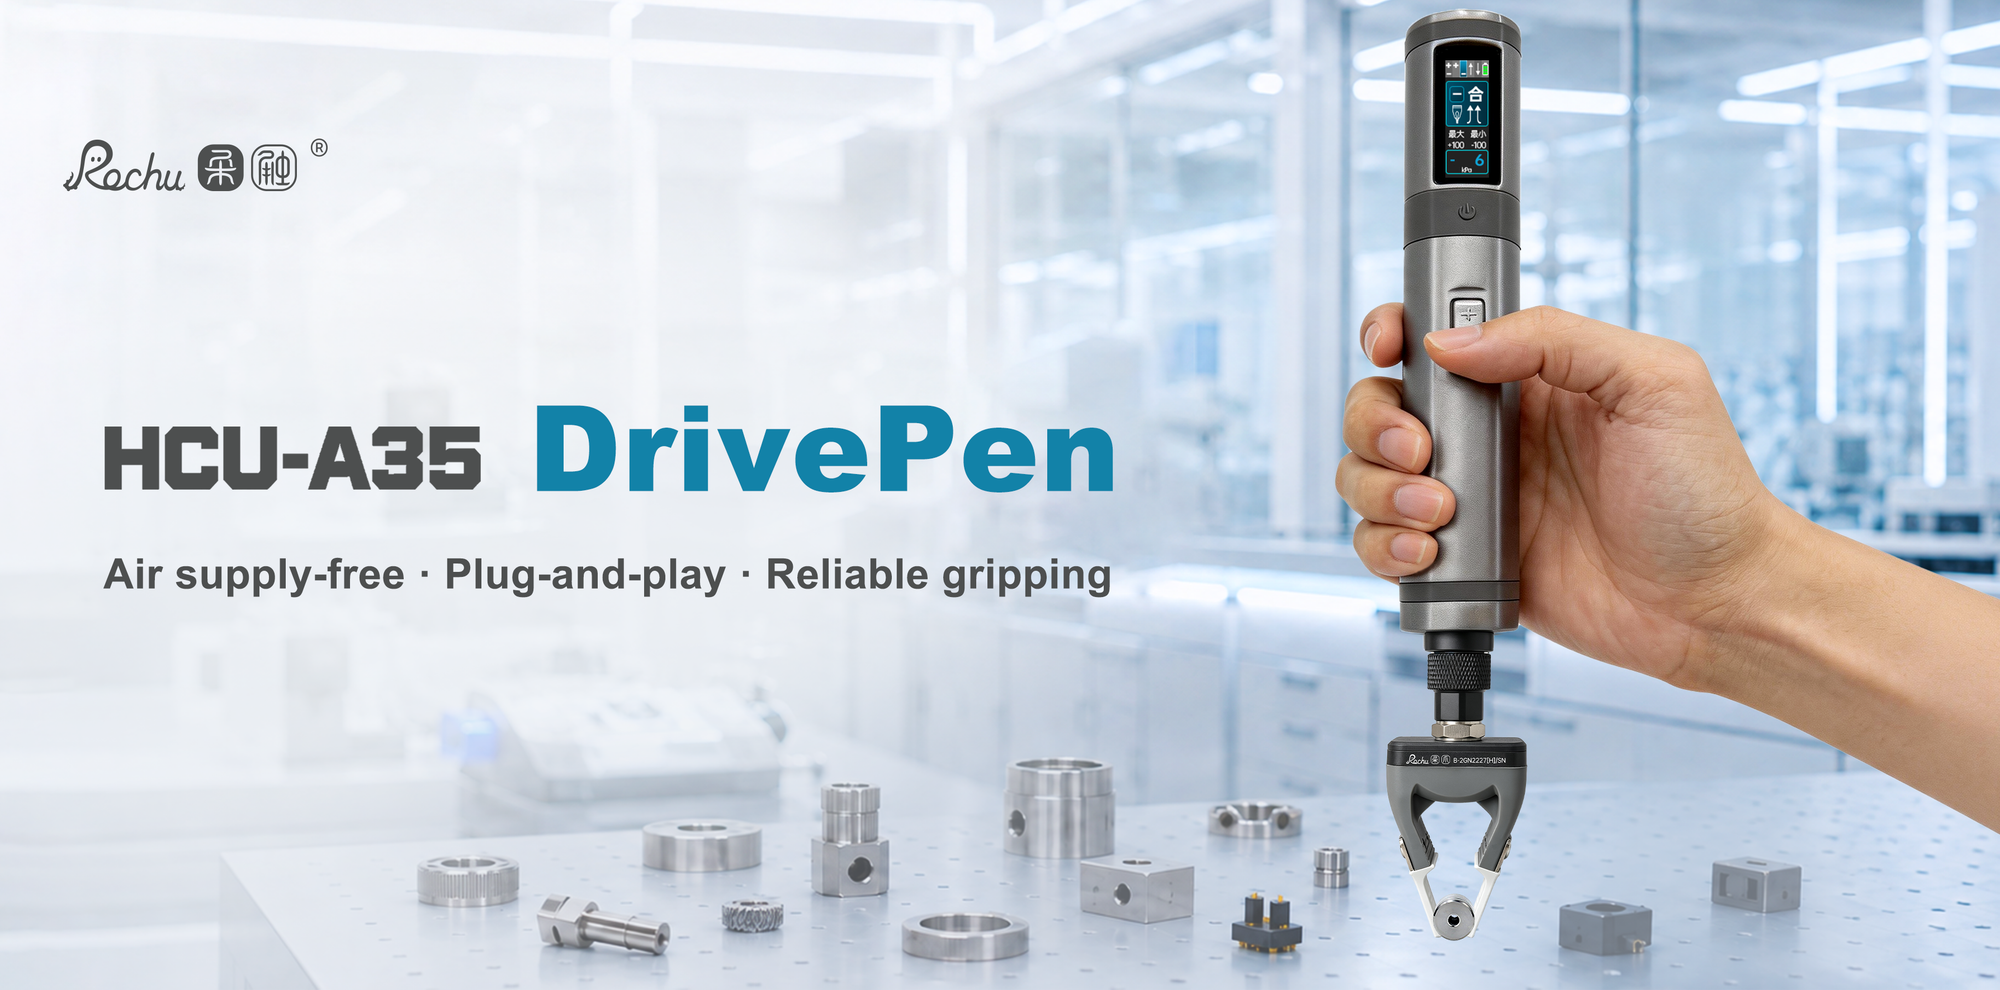
The application of pneumatic soft grippers in industrial handling is expanding at an accelerating pace. However, conventional deployment paths depend heavily on fixed air lines, compressed air sources, and robotic arm platforms — driving up system costs and lead times, and creating a significant bottleneck for rapid validation and flexible deployment.
The Deployment Dilemma of Pneumatic Grippers
At the solution-selection stage, engineers often face a familiar dilemma: when confronted with a customer's irregularly shaped workpiece, they cannot be sure whether a soft gripper can handle it — yet verifying feasibility requires building a complete pneumatic setup. From air compressor selection and tubing to robot arm integration, the upfront preparation takes days and often costs tens of thousands of RMB. And if the test results fall short, that entire investment is sunk.
Moreover, some production lines are in a transitional phase, migrating from manual operation to automation — not yet ready for fully automated deployment, yet unable to justify the heavy capital outlay of a robotic arm system. The industry needs an intermediate solution between lab validation and fully automated production lines.
The HCU-A35 Handheld Electric Soft Gripper is a self-contained pneumatic drive unit built precisely to fill this gap — a grab-and-go tool.
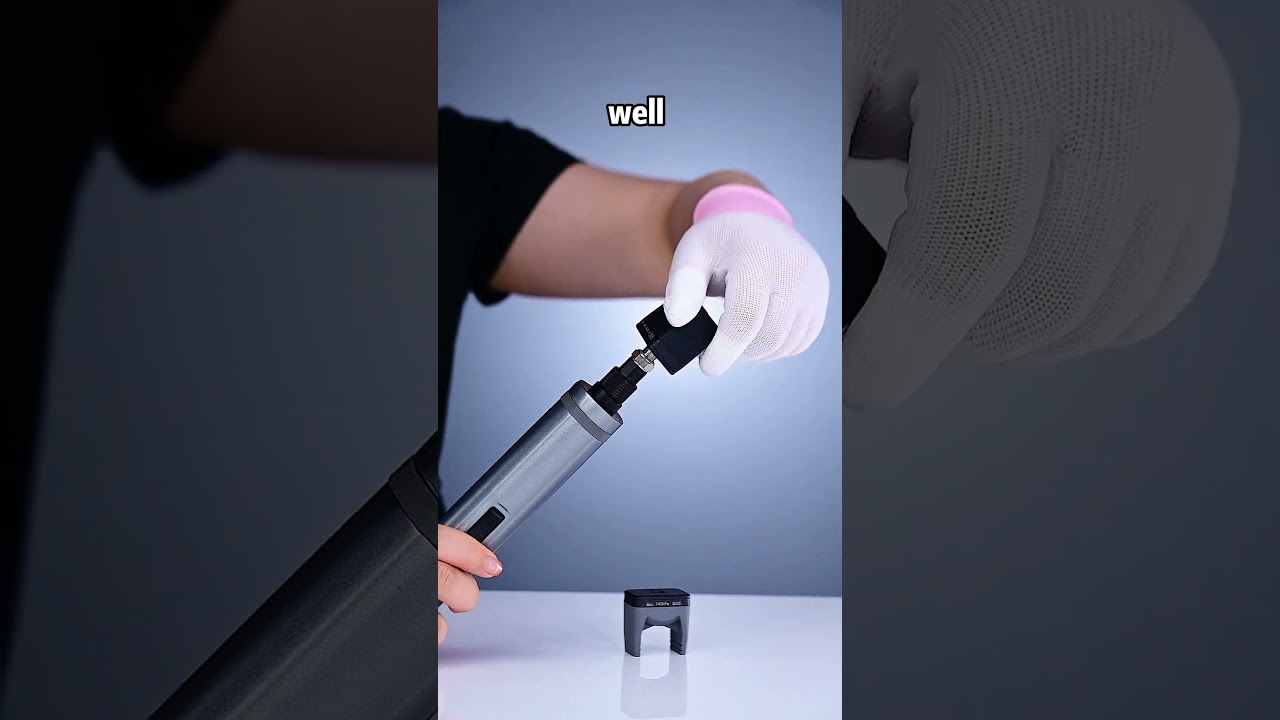
01 Plug-and-Play, Instant Setup
Operation is simplified to three steps: attach the soft gripper or suction end effector, power on, and use two independent buttons to control vacuum (grip/close) and positive pressure (release/open). No complex pneumatic parameter tuning, no control programming, no test rig construction — just charge it and it's ready to use
02 Rapid Grab-Feasibility Validation
During solution selection and pre-sales assessment, engineers can take the HCU-A35 directly to the customer's site for on-the-spot grab testing of new workpieces. Through hands-on operation, they can determine within one minute whether a soft gripper suits the workpiece — including grip stability, the vacuum level required, and the optimal gripping angle. No waiting for air-line installation, robot arm commissioning, or procurement approvals.
03 Assisted Handling for Manual Sorting
For irregular, fragile, or surface-sensitive workpieces, bare-hand manual picking is slow and prone to surface damage. Paired with a soft gripper end effector, the HCU-A35 enables operators to perform flexible, conformal wrapping grips by hand — maintaining handling efficiency while preventing hard contact from damaging workpiece surfaces. Compared with full robotic arm solutions, the cost is kept at a far lower order of magnitude.
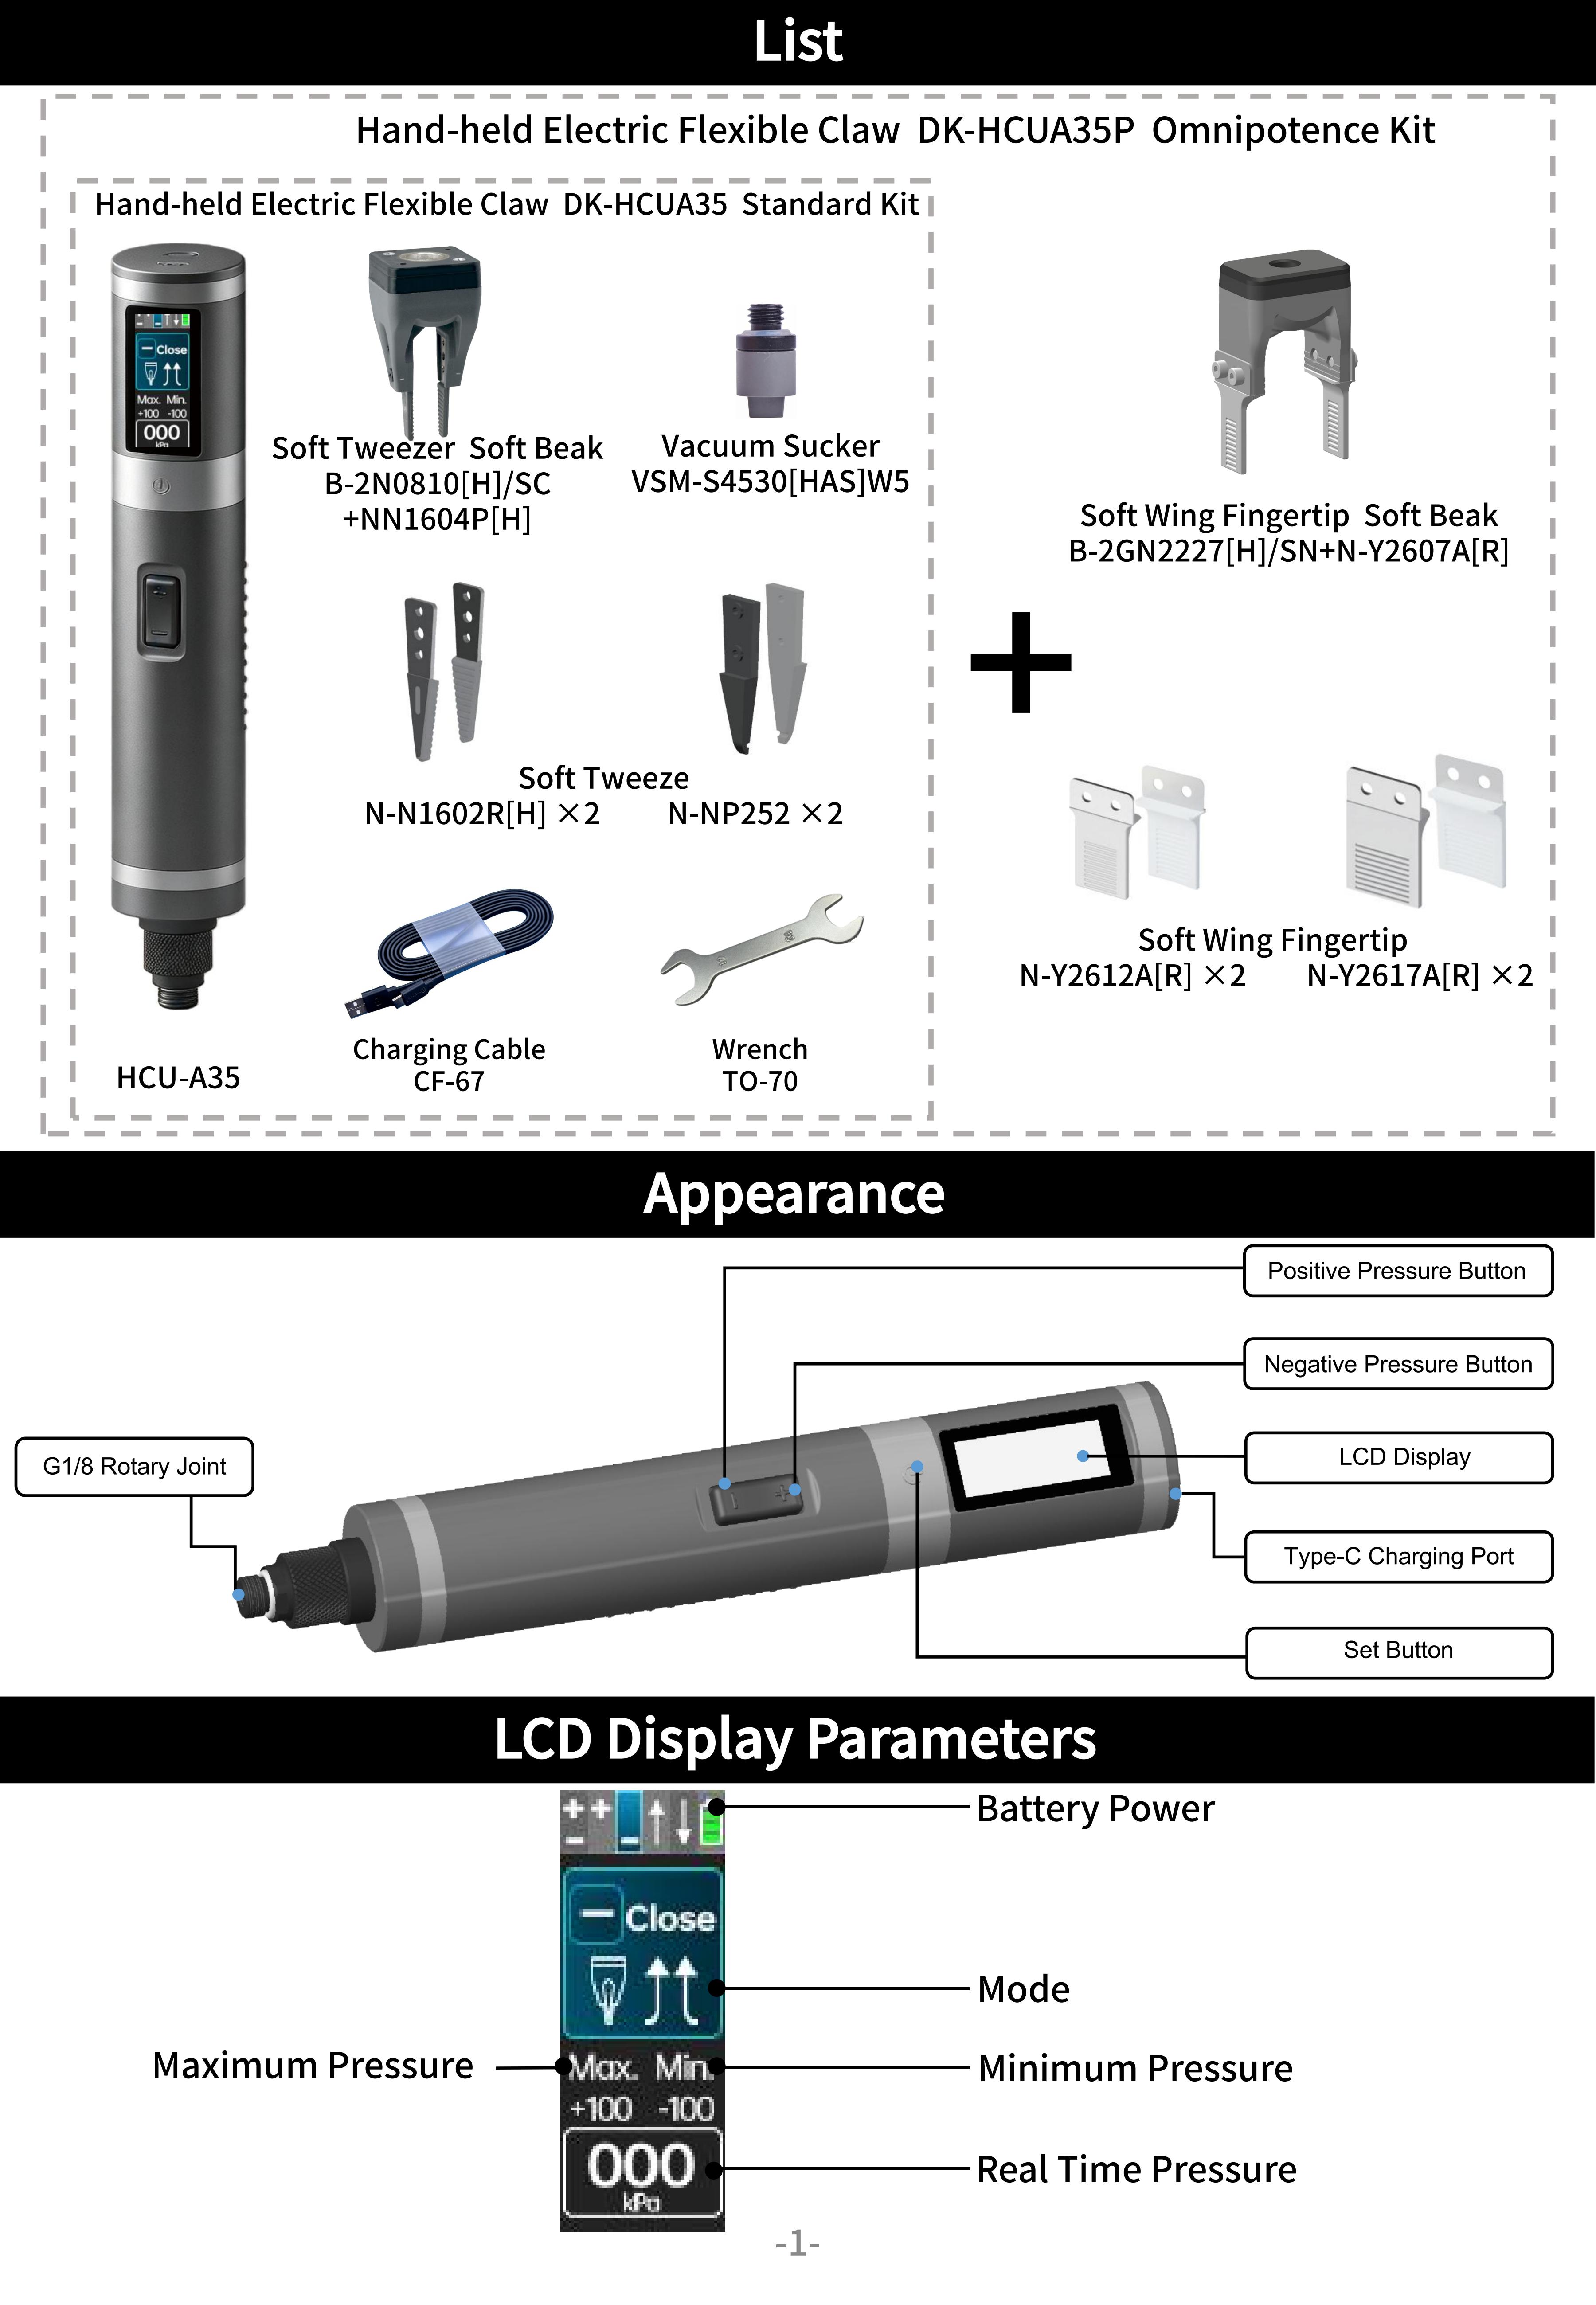
In automation, the most expensive thing is rarely the equipment — it's uncertainty. Uncertain whether it can grip. Uncertain whether it's worth the investment. Uncertain whether to commit.What the HCU-A35 fundamentally does is dissolve that uncertainty: compressing validation cost from the system level down to the tool level, so engineers can get a definitive answer before committing heavy resources.A technology's path to scale is never determined by leading-edge spec sheets — it's determined by how low the barrier to "just give it a try" can go.